Multibeam Echosounder
EM2042 dual-head, quad-swath multibeam on the retractable gondola - the primary bathymetric sensor, to IHO survey standards.
Applications & payloads
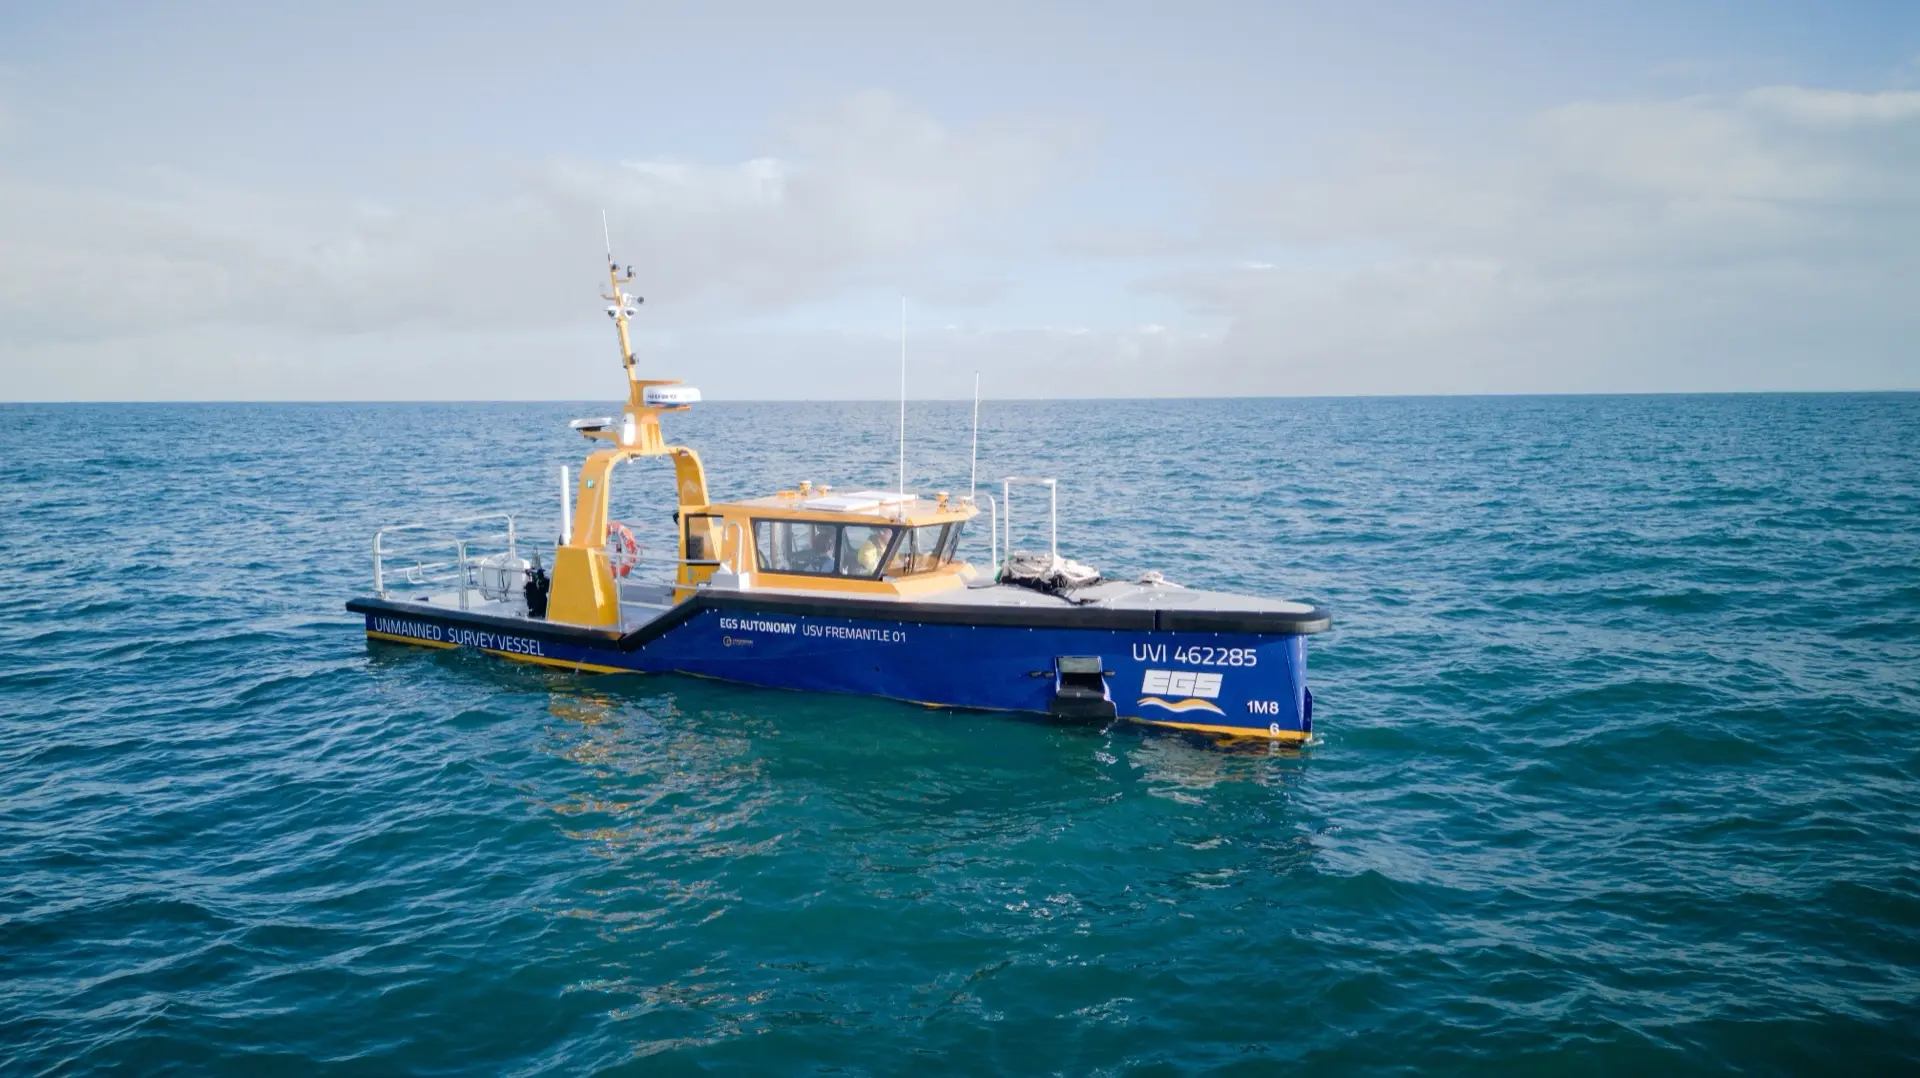
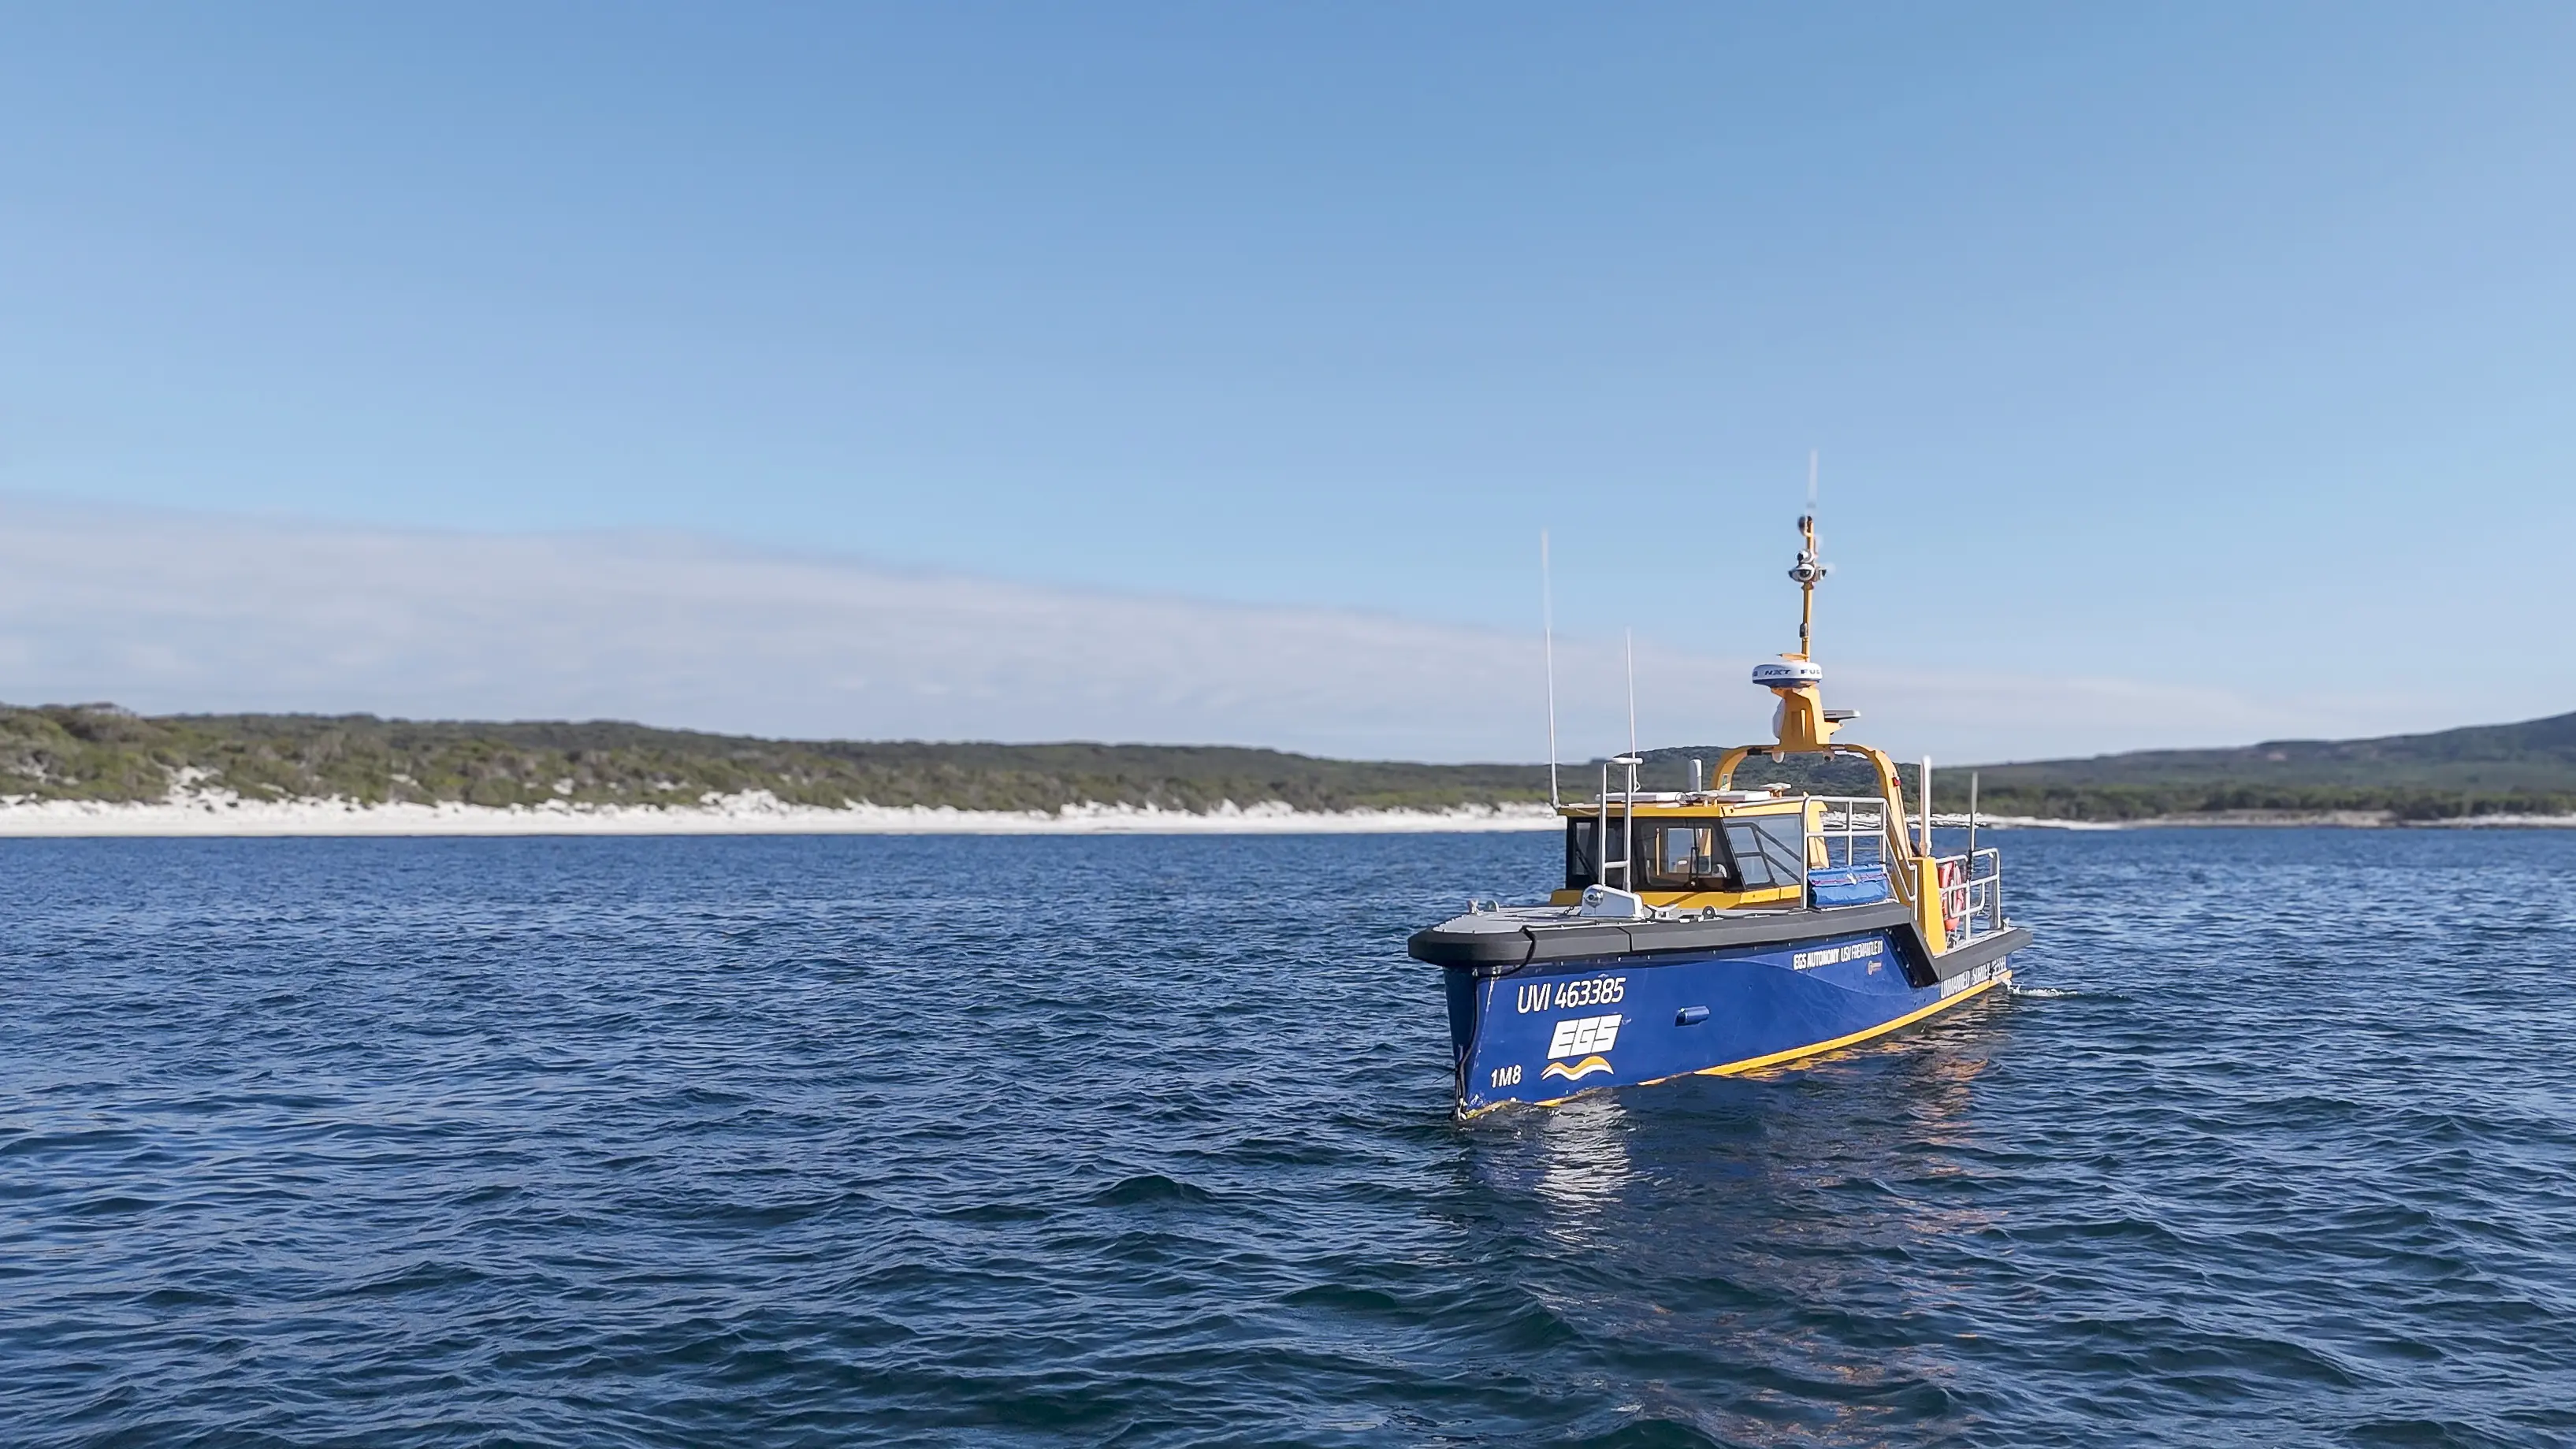
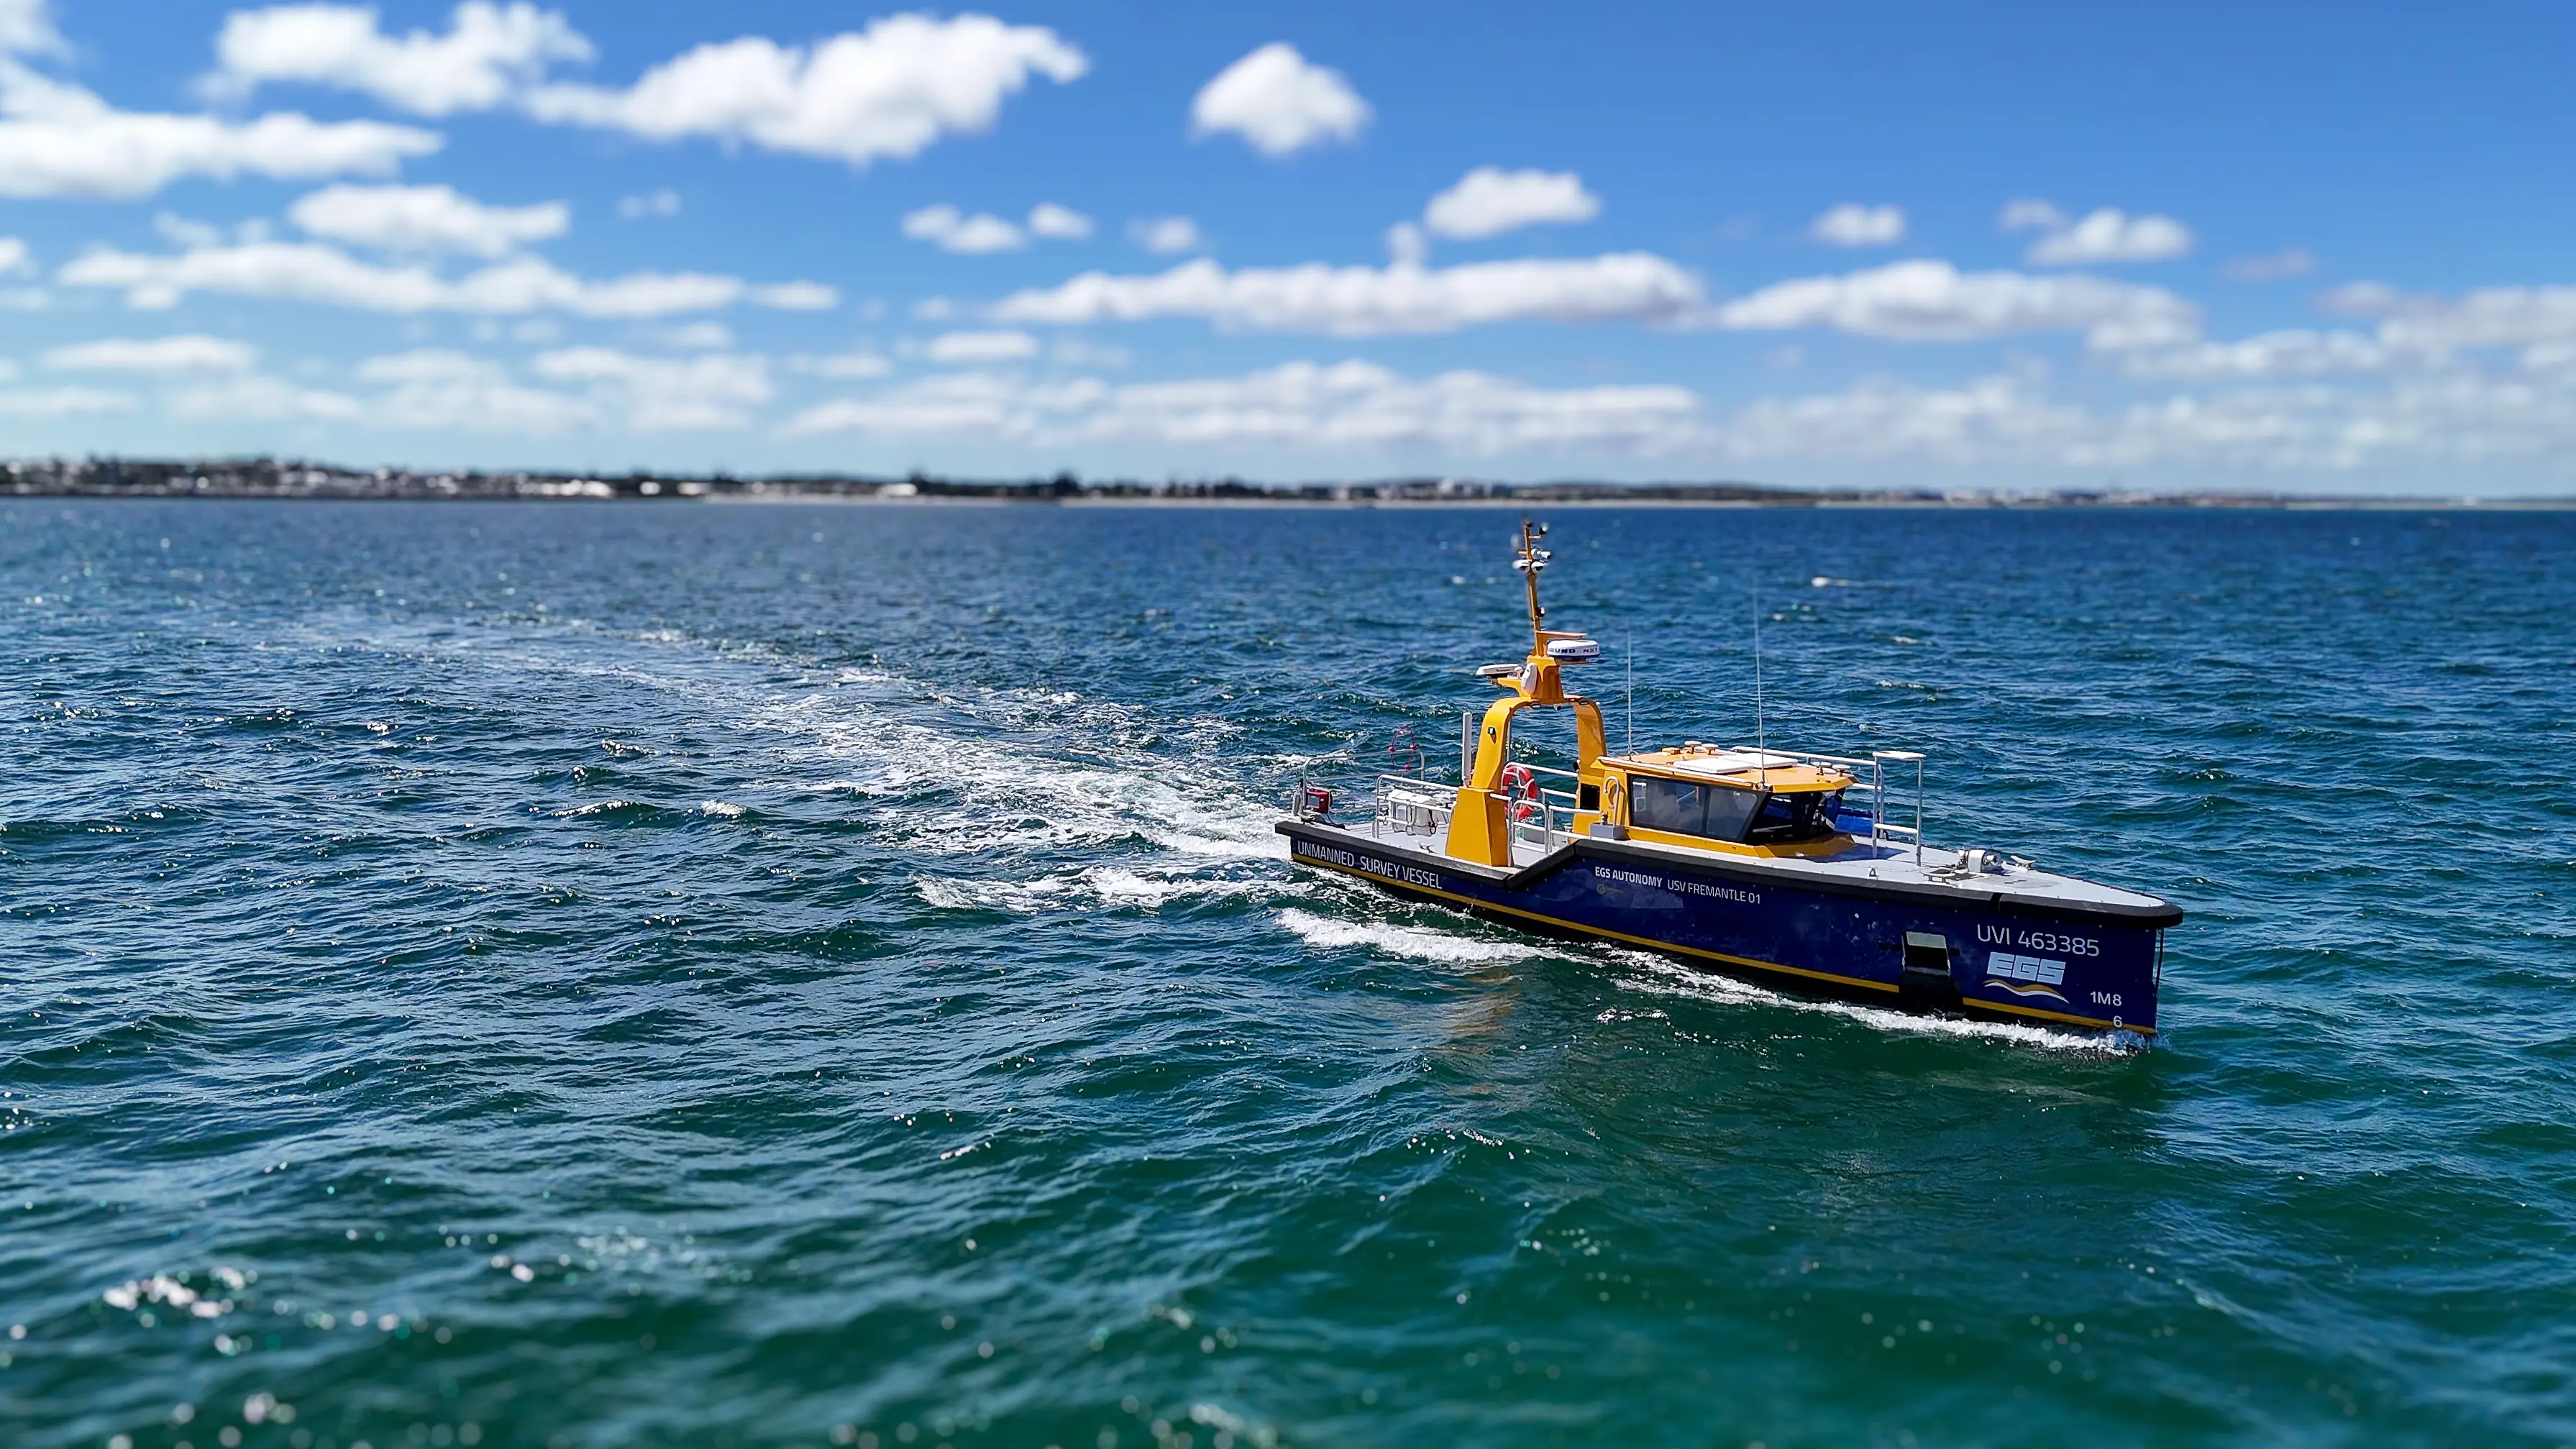
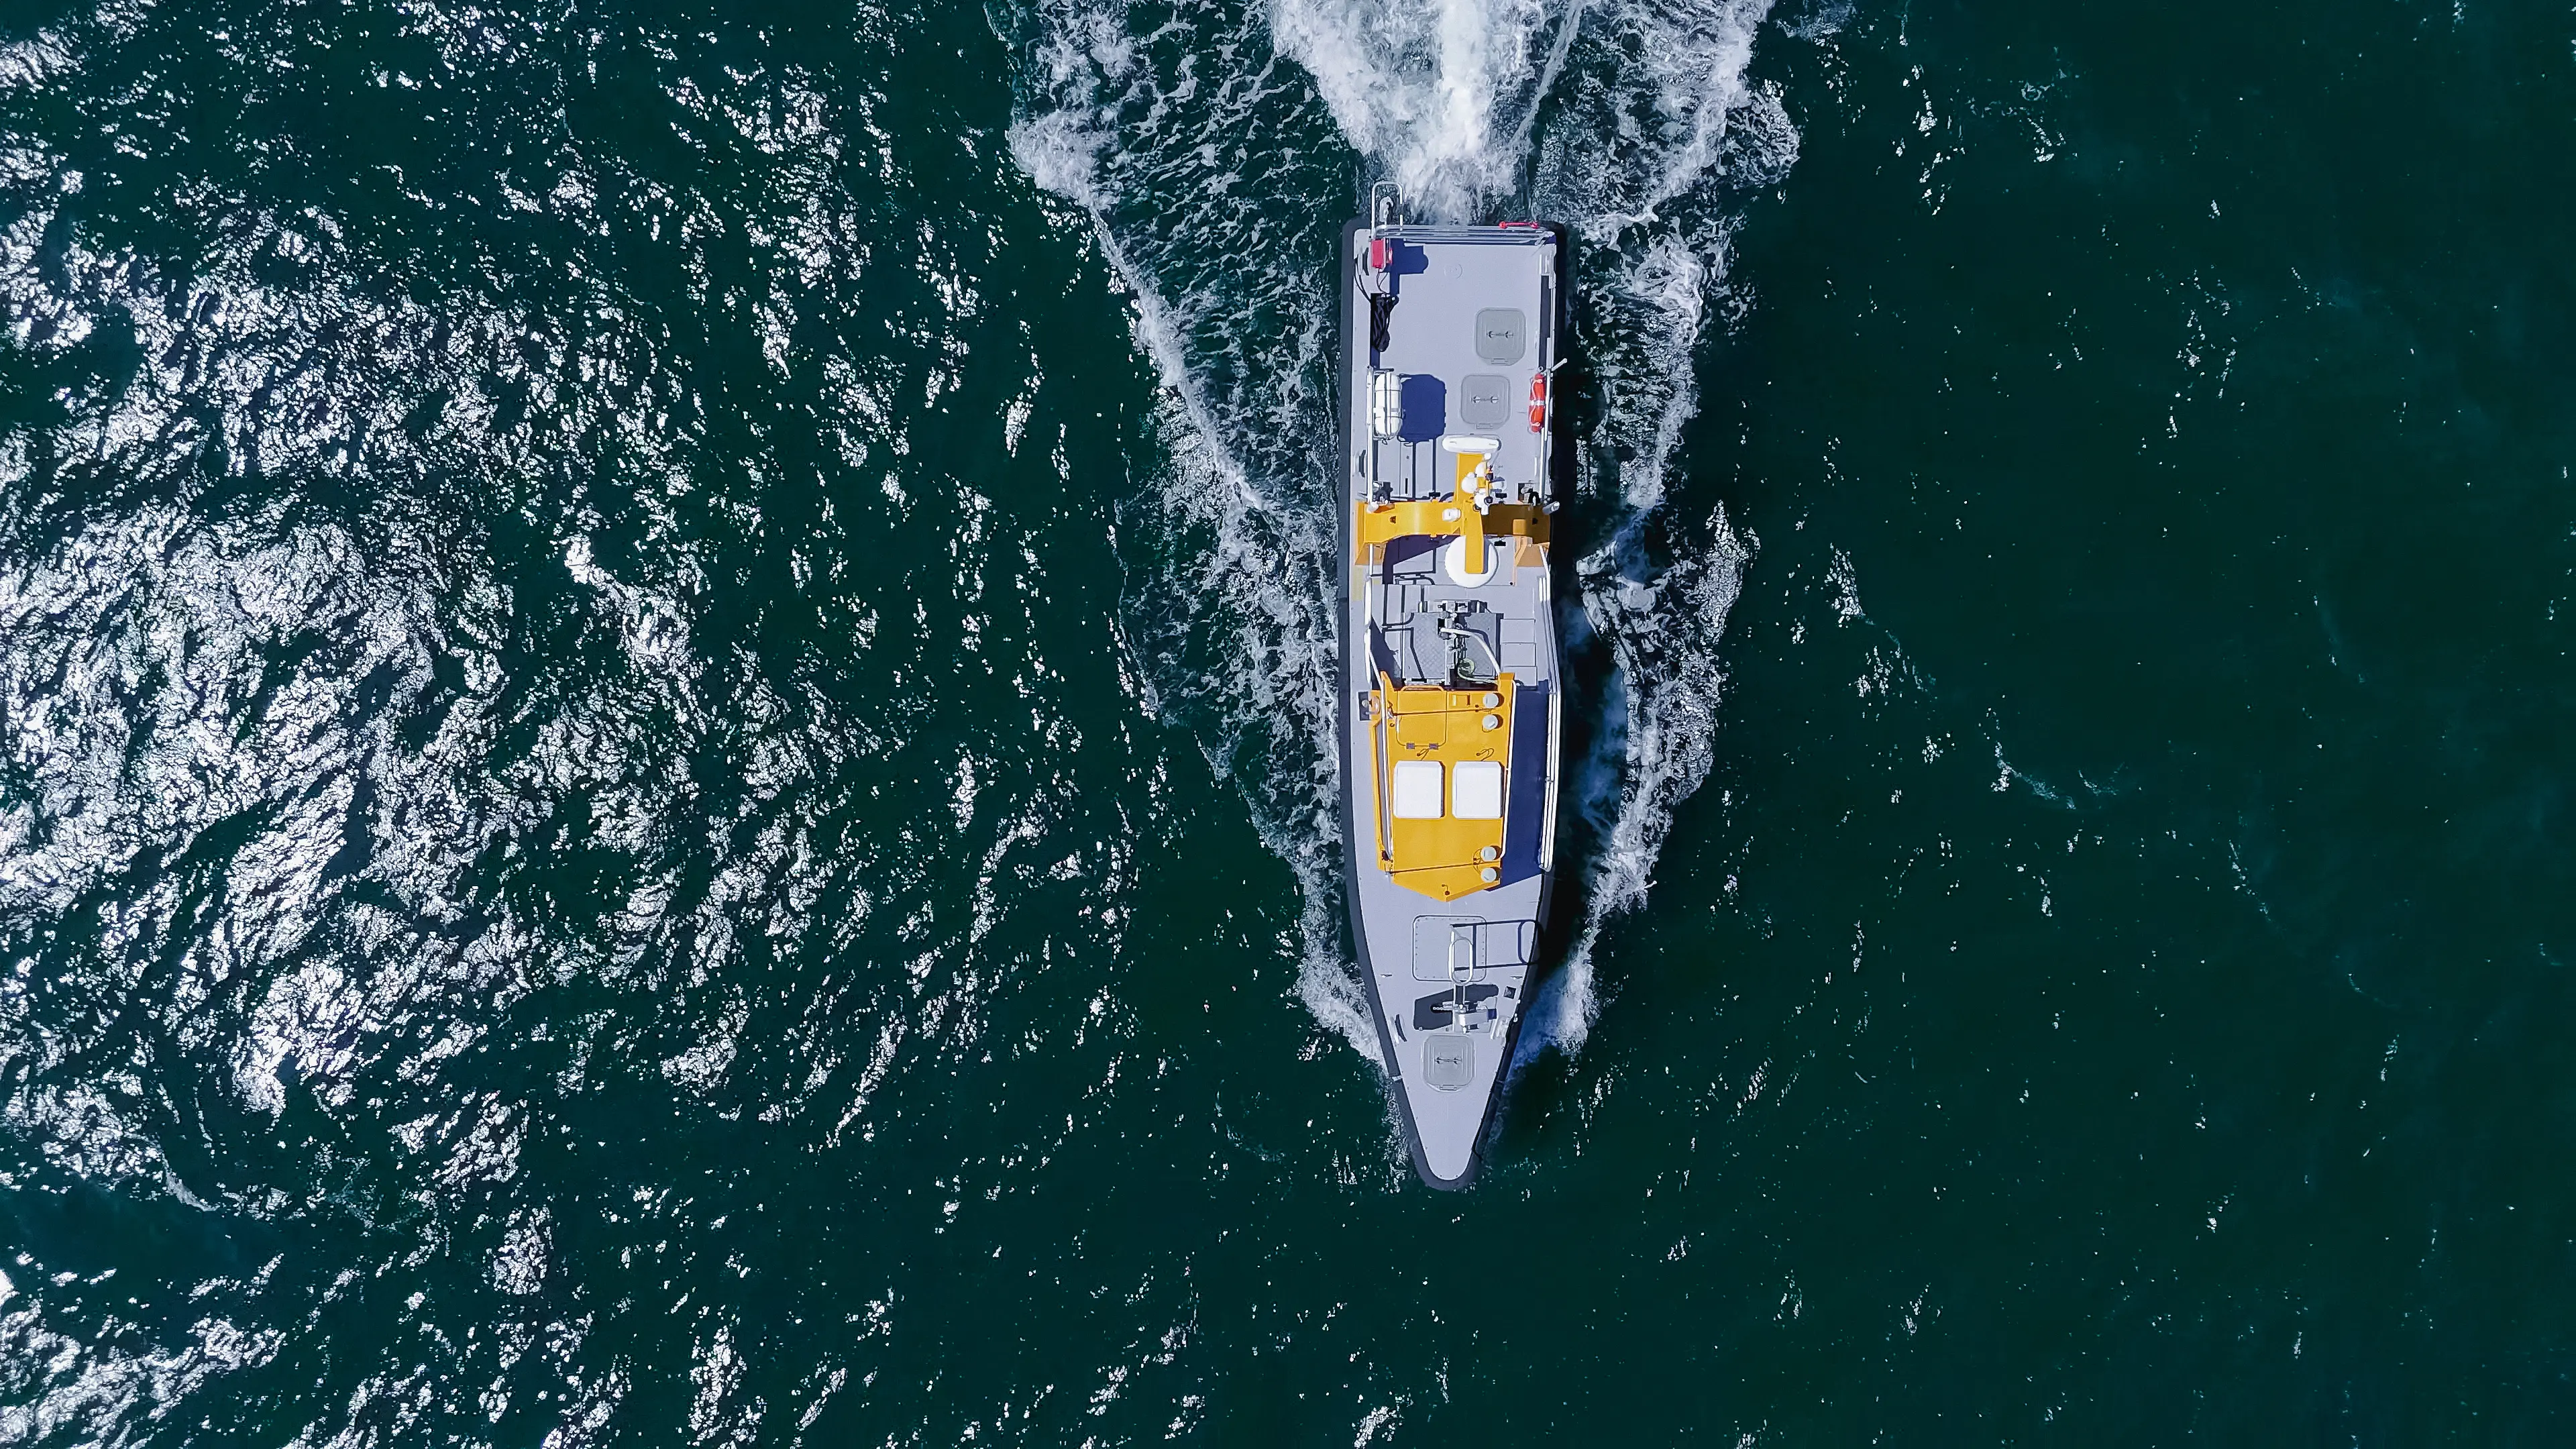
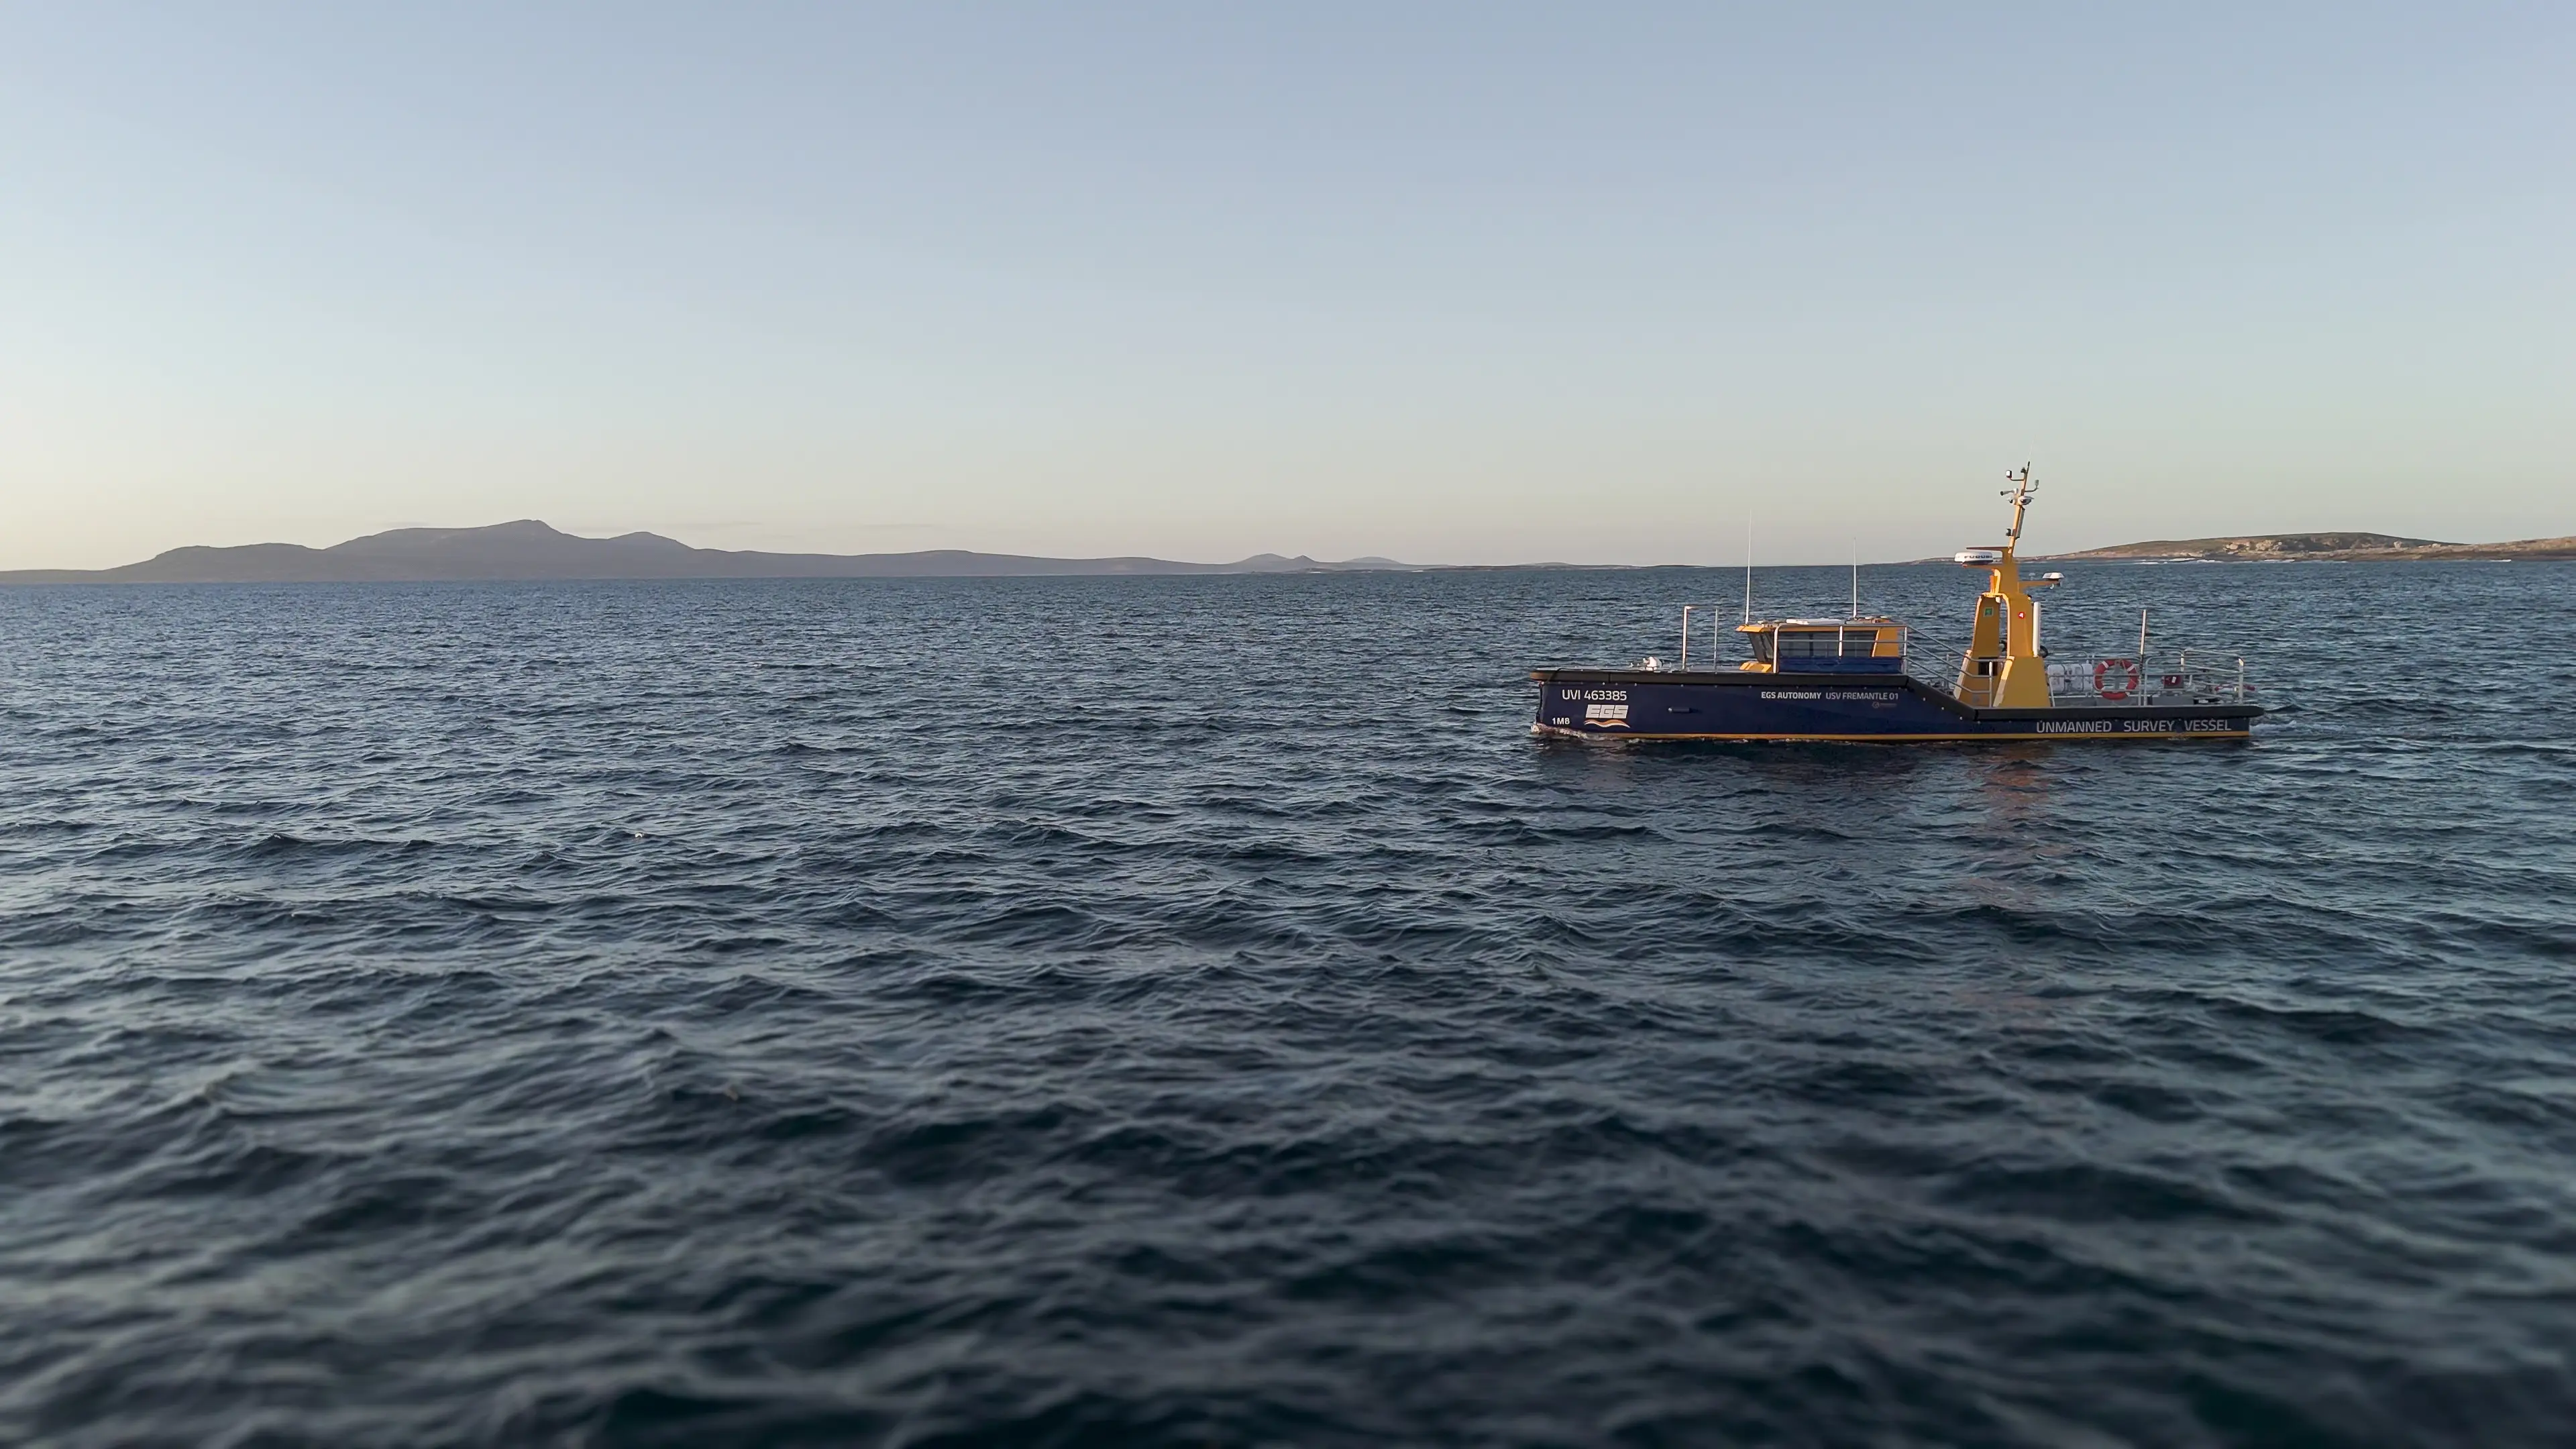
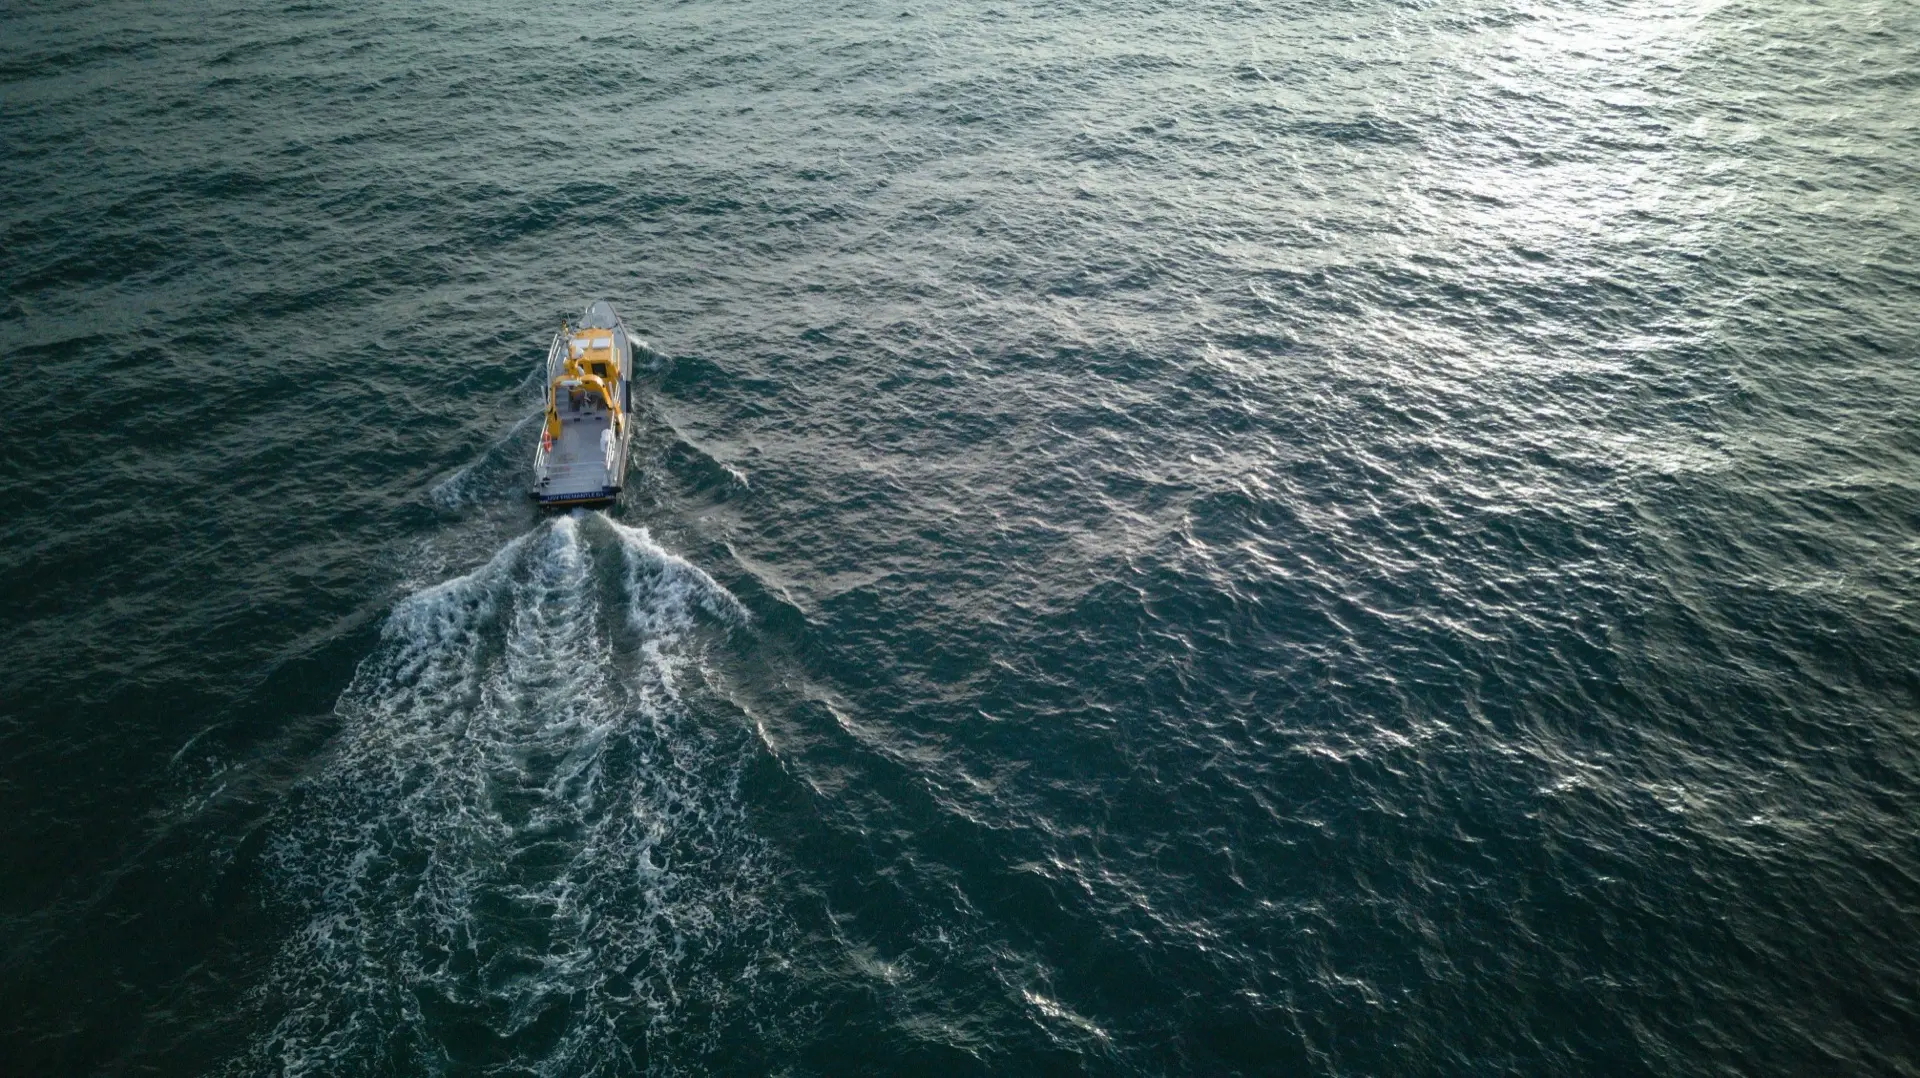
The EGS Autonomy fleet is a modular, flexible design configured to suit specific survey and customer requirements. EGS can integrate alternative equipment, with the larger 20 m variants carrying deck-launched payloads.
Standard survey equipment
As fitted to the first vessels - mounted on the retractable gondola and across the deck, integrated with the survey acquisition suite. Common across the fleet.
EM2042 dual-head, quad-swath multibeam on the retractable gondola - the primary bathymetric sensor, to IHO survey standards.
Innomar standard sub-bottom profiler for shallow sub-seabed structure - sediment thickness, buried features and stratigraphy.
EdgeTech 4200-series side-scan for geophysical survey, with magnetometer capability for ferrous-target and pipeline/cable detection.
Applanix POS MV inertial navigation and GNSS, integrated with the multibeam and acquisition software for precise position and motion compensation.
20 m variants
On the dynamically-positioned 20 m variants, EGS's payload-agnostic launch-and-recovery system handles deployed payloads across the inspection-to-work-class range - selected to suit the task.
A stern-mounted A-frame or crane with winch, over-boarding sheave and fairlead deploys a remotely-operated towed payload, sized to the required depth and survey speed.
Cradle, capture and handling for a deck-deployed AUV, launched for off-board autonomous survey and recovered on completion.
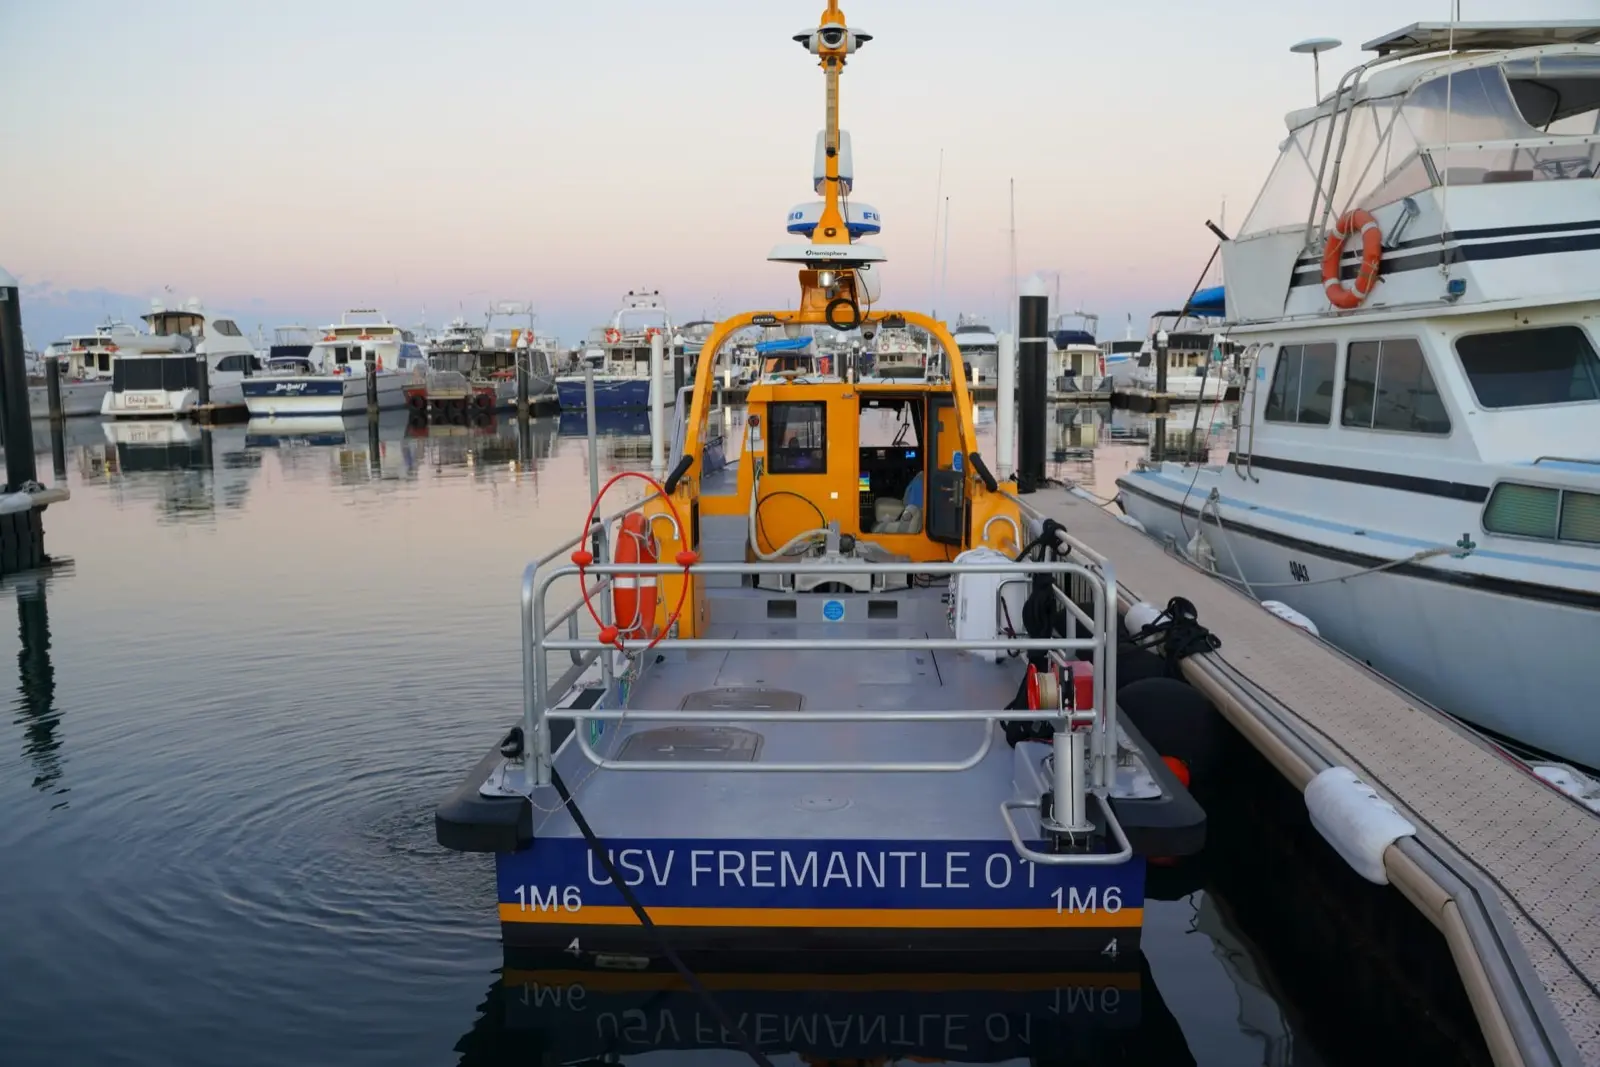
Payload-agnostic ROV launch and recovery from the after deck, from inspection-class through to work-class ROVs with manipulator capability.